I work at the boundary between robotics research and shipped engineering. My academic work asks how humanoid robots should communicate so that people trust them appropriately: not too little, not too much. My applied work is the planners, verification layers and embedded firmware those robots run on.
I hold both to one standard: a stranger should be able to reproduce every number, and every project should say where it stops.
The robots I have worked on.
The gesture and speech pipeline for my MSc study, from an Isaac Sim digital twin to the real robot, run with 20 participants.
TensorFlow models tuned for real-time inference, to the latency budget a walking controller leaves for perception.
The platform my A* and D* Lite planner plugins, the safety verifier and the shield are written for.
Deterministic motion-detection firmware and the LoRa mesh alerts, built under contract for Muxtronics.
Stylised models drawn for this site, not product renders.
What I have withdrawn.
Three projects have withdrawn earlier claims, and each page says so where the claim stood: field-trial accuracy figures on the ESP32-CAM page, hardware results on the safety verifier page, and a decay exponent and four constants on the blowup page. The repositories record what was withdrawn and why.
Where I have worked.
Teach Computing Principles and Logic, a first-year module of the University of London BSc Artificial Intelligence taught at UCLTILS.
Sole engineer of the institute's live platform, in production across seven user roles and 33 audited tables.
Designed and teach an ML curriculum for 30+ students with no prior background, taking teams through training and evaluating their own classifiers on custom tasks.
Deterministic C++ firmware for real-time image processing on ESP32, and the LoRa mesh protocol that carried alerts off the device, for a commercial intrusion-detection prototype.
Built the gesture recognition and motion planning pipeline for the JD humanoid in Unity and C++, integrated through ROS2, and deployed PyTorch non-verbal communication models onto its real-time control loop.
Fine-tuned and optimised TensorFlow models for real-time inference on the Unitree Go1 quadruped, to the latency budget a walking controller leaves for perception.
Optimised bare-metal C firmware for embedded controllers at the national robotics centre, validated across 100+ safety-critical test cycles.
What they said.
“From the initial stages of designing interactive scenarios for the robot to conducting experiments with human participants and analysing results, Munawar demonstrated remarkable technical proficiency, creativity, and a strong work ethic.”
“Munawar demonstrated exceptional skill in embedded AI deployment during his contract at Muxtronics, leading the ESP32-CAM prototype from concept to a working product.”
“Money cannot be quietly deleted: a wrong payment is corrected by a recorded reversal, so the record of what happened survives. And every change anyone makes is logged automatically. He proposed both of these himself. I did not ask for them, and I did not know to.”
In front of a room.
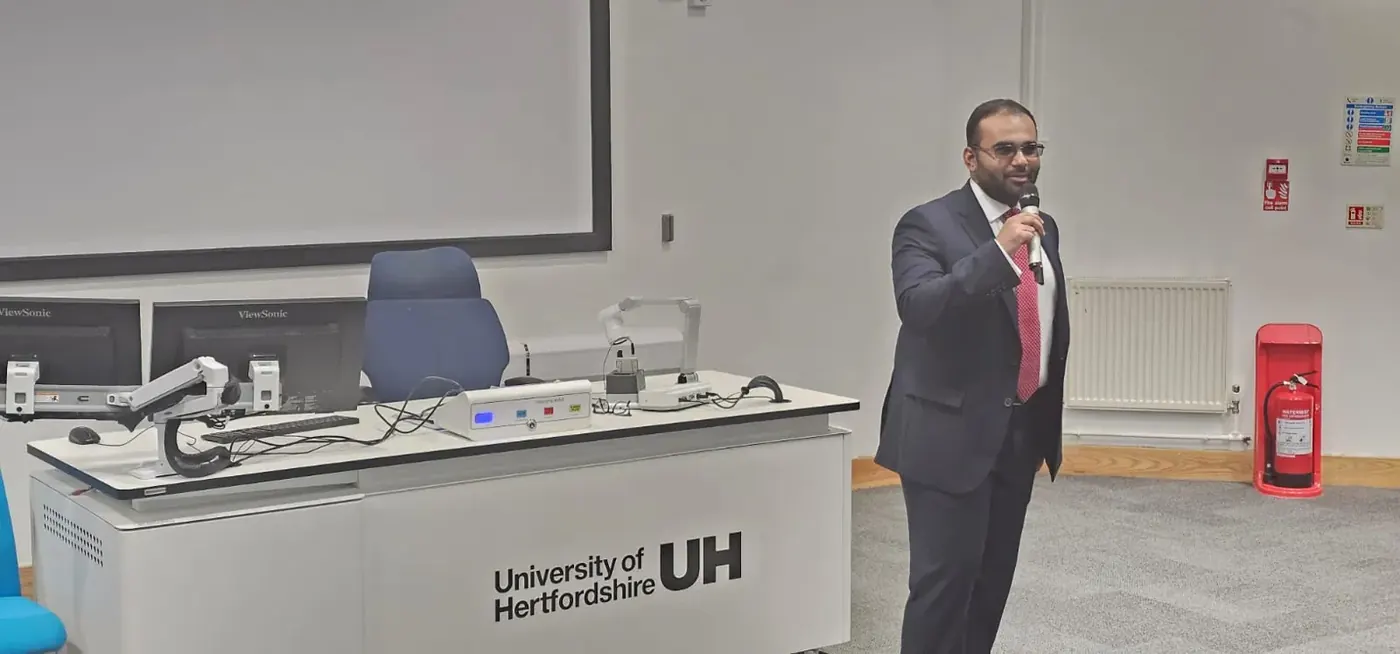 AI & Robotics in Education ConferenceTalk · University of Hertfordshire · 2024
Presented on HRI and edge AI applications to students and faculty, with live robot demonstrations of the companionship research.
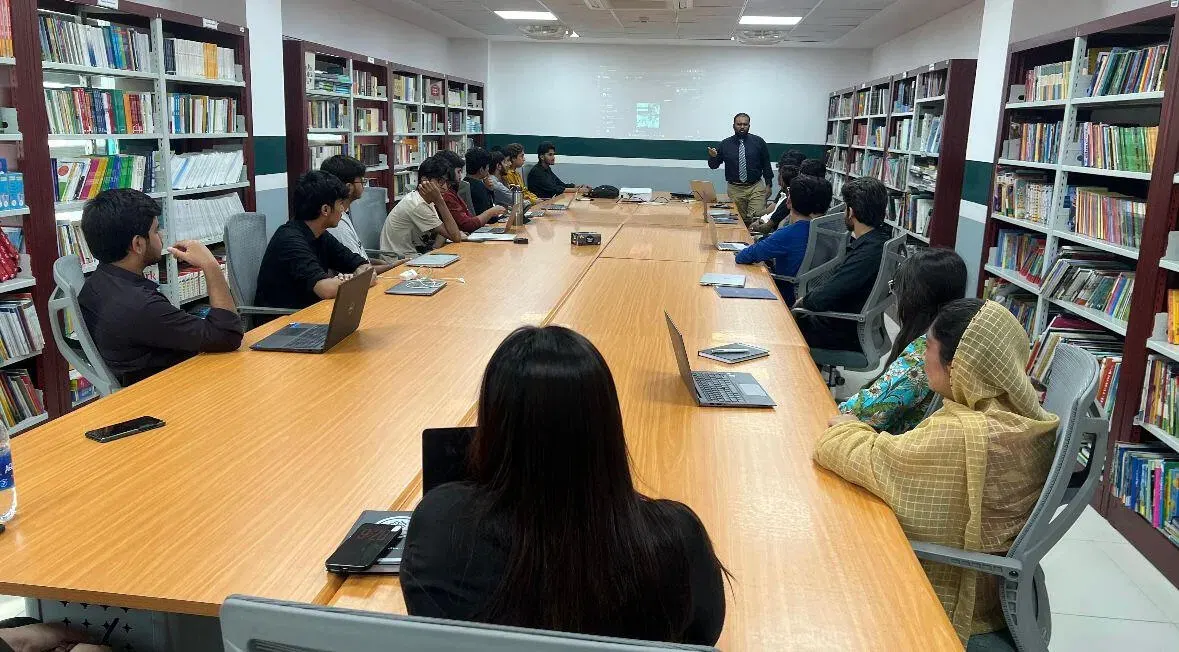 Hands-on robotics and ML workshopWorkshop · Pak-Turk Maarif Schools · 2025
Led practical sessions covering gesture control, neural networks and real-time AI deployment. Teams built and trained working classifiers during the session.